8.1.2. ROS Commands and Tools#
8.1.2.1. Head joint control#
Control the head joints below via an action
Joint name
Command value
head_pan_joint1.0[rad]
head_tilt_joint0.5[rad]
$ ros2 action send_goal /head_trajectory_controller/follow_joint_trajectory control_msgs/action/FollowJointTrajectory "{trajectory: {joint_names: ["head_pan_joint", "head_tilt_joint"], points: [{positions: [1.0, 0.5], time_from_start: {sec: 2.0}}]}}"
Get the current state of the head controller as published
$ ros2 topic echo /head_trajectory_controller/controller_state
header:
  stamp:
    sec: 1647835540
    nanosec: 104428359
  frame_id: ''
  joint_names:
  - head_tilt_joint
  - head_pan_joint
  desired:
  positions:
  - 0.5
  - 1.0
  velocities:
  - 0.0
  - 0.0
  accelerations:
  - 0.0
  - 0.0
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
actual:
  positions:
  - 0.5002282179067921
  - 0.9999919034998204
  velocities: []
  accelerations: []
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
error:
  positions:
  - -0.0002282179067920609
  - 8.096500179632926e-06
  velocities: []
  accelerations: []
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
Send the following command to the subscriber that sets the target trajectory
Joint name
Command value
head_pan_joint0.5[rad]
head_tilt_joint1.0[rad]
$ ros2 topic pub --once /head_trajectory_controller/joint_trajectory trajectory_msgs/msg/JointTrajectory "{joint_names: ["head_pan_joint", "head_tilt_joint"], points: [{positions: [0.5, 1.0], time_from_start: {sec: 3.0}}]}"
8.1.2.2. Arm joint control#
Control the arm joints below via an action
Joint name
Command value
arm_flex_joint0.0[rad]
arm_lift_joint0.2[m]
arm_roll_joint-1.57[rad]
wrist_flex_joint-1.57[rad]
wrist_roll_joint0.0[rad]
$ ros2 action send_goal /arm_trajectory_controller/follow_joint_trajectory control_msgs/action/FollowJointTrajectory "{trajectory: {joint_names: ["arm_flex_joint", "arm_lift_joint", "arm_roll_joint", "wrist_flex_joint", "wrist_roll_joint"], points: [{positions: [0.0, 0.2, -1.57, -1.57, 0.0], time_from_start: {sec: 5.0}}]}}"
Get the current state of the arm controller as published
$ ros2 topic echo /arm_trajectory_controller/controller_state
header:
  stamp:
    sec: 1647835459
    nanosec: 69912926
  frame_id: ''
  joint_names:
  - arm_lift_joint
  - arm_flex_joint
  - arm_roll_joint
  - wrist_flex_joint
  - wrist_roll_joint
  desired:
  positions:
  - 0.2
  - 0.0
  - -1.57
  - -1.57
  - 0.0
  velocities:
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  accelerations:
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
actual:
  positions:
  - 0.19970873540096648
  - -1.9862772813183938e-06
  - -1.5700972685438084
  - -1.5695222863478908
  - 1.4550485046171957e-05
  velocities: []
  accelerations: []
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
error:
  positions:
  - 0.0002912645990336138
  - 1.9862772813183938e-06
  - 9.72685438083154e-05
  - -0.00047771365210902417
  - -1.4550485046171957e-05
  velocities: []
  accelerations: []
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
Send the following command to the subscriber that sets the target trajectory
Joint name
Command value
arm_flex_joint0.0[rad]
arm_lift_joint0.0[m]
arm_roll_joint-1.57[rad]
wrist_flex_joint-1.57[rad]
wrist_roll_joint0.0[rad]
$ ros2 topic pub --once /arm_trajectory_controller/joint_trajectory trajectory_msgs/msg/JointTrajectory "{joint_names: ["arm_flex_joint", "arm_lift_joint", "arm_roll_joint", "wrist_flex_joint", "wrist_roll_joint"], points: [{positions: [0.0, 0.0, -1.57, -1.57, 0.0], time_from_start: {sec: 3.0}}]}"
8.1.2.3. Hand control#
Control the hand below via an action
Joint name
Command value
hand_motor_joint1.0[rad]
$ ros2 action send_goal /gripper_controller/follow_joint_trajectory control_msgs/action/FollowJointTrajectory "{trajectory: {joint_names: ["hand_motor_joint"], points: [{positions: [1.0], time_from_start: {sec: 2.0}}]}}"
Control the gripper by specifying the distance between the fingertips using an action
$ ros2 action send_goal /gripper_controller/set_distance tmc_control_msgs/action/GripperSetDistance "{distance: 0.05}"
Control the gripper by specifying the trajectory of the distance between the fingertips using an action
$ ros2 action send_goal /gripper_controller/follow_distance_trajectory control_msgs/action/FollowJointTrajectory "{trajectory: {joint_names: ["hand_motor_joint"], points: [{positions: [0.05], time_from_start: {sec: 5}}]}}"
apply_force with the force specified by the action (1.0 N)
$ ros2 action send_goal /gripper_controller/grasp tmc_control_msgs/action/GripperApplyEffort "{effort: -1.0}"
Grasp with the force specified by the action (1.0 N)
$ ros2 action send_goal /gripper_controller/apply_force tmc_control_msgs/action/GripperApplyEffort "{effort: 1.0}"
Send the following command to the subscriber that sets the target trajectory
Joint name
Command value
hand_motor_joint1.0[rad]
$ ros2 topic pub --once /gripper_controller/joint_trajectory trajectory_msgs/msg/JointTrajectory "{joint_names: ["hand_motor_joint"], points: [{positions: [1.0], time_from_start: {sec: 3.0}}]}"
Send the following command to the subscriber that sets the fingertip distance.
Command value
0.05[m]
$ ros2 topic pub --once /gripper_controller/command_distance std_msgs/msg/Float32 "{data: 0.05}"
Send the following command to the subscriber that sets the target trajectory of the fingertip distance
Joint name
Command value
hand_motor_joint0.05[m]
$ ros2 topic pub --once /gripper_controller/distance_trajectory trajectory_msgs/msg/JointTrajectory "{joint_names: ['hand_motor_joint'], points: [{positions: [0.05], time_from_start: {sec: 5}}]}"
8.1.2.4. Mobile base control#
Send an action goal to perform the mobile base trajectory below
Joint name
Command value
odom_x0.5[m]
odom_y0.0[m]
odom_t0.0[rad]
$ ros2 action send_goal /omni_base_controller/follow_joint_trajectory control_msgs/action/FollowJointTrajectory "{trajectory: {joint_names: ["odom_x", "odom_y", "odom_t"], points: [{positions: [0.5, 0.0, 0.0], time_from_start: {sec: 3.0}}]}}"
Get the currently published state of the mobile base controller
$ ros2 topic echo /omni_base_controller/state
header:
  stamp:
    sec: 1647836100
    nanosec: 780639190
  frame_id: ''
joint_names:
- odom_x
- odom_y
- odom_t
desired:
  positions: []
  velocities: []
  accelerations: []
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
actual:
  positions:
  - 0.0
  - 0.0
  - 0.0
  velocities:
  - -0.0010223520662738157
  - 6.758229886193314e-05
  - -0.2545051782656925
  accelerations: []
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
error:
  positions: []
  velocities: []
  accelerations: []
  effort: []
  time_from_start:
    sec: 0
    nanosec: 0
Use this service to retrieve the currently published wheel odometry from system start
$ ros2 topic echo /omni_base_controller/wheel_odom
header:
  stamp:
    sec: 1647836473
    nanosec: 646157354
  frame_id: odom
child_frame_id: base_footprint_wheel
pose:
  pose:
    position:
      x: -9.0851020155767
      y: -5.075906977696168
      z: 0.0
    orientation:
      x: -0.0
      y: -0.0
      z: -0.5359724394722091
      w: 0.8442354790733502
  covariance:
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
twist:
  twist:
    linear:
      x: -0.0010379325663322169
      y: 6.24562721239427e-05
      z: 0.0
    angular:
      x: 0.0
      y: 0.0
      z: -0.24736113963905038
  covariance:
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
  - 0.0
Send a command to the subscriber that sets the target velocity
$ ros2 topic pub --once /omni_base_controller/cmd_vel geometry_msgs/msg/Twist "{linear: {x: 1.0, y: 0.0, z: 0.0}, angular: {x: 0.0, y: 0.0, z: 0.0}}"
8.1.2.5. Hand camera#
Get the published camera information
$ ros2 topic echo /hand_camera/camera_info
header:
  stamp:
    sec: 10068
    nanosec: 857000000
  frame_id: hand_camera_frame
height: 480
width: 640
distortion_model: plumb_bob
d:
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
k:
- 205.46963709898583
- 0.0
- 320.5
- 0.0
- 205.46963709898583
- 240.5
- 0.0
- 0.0
- 1.0
r:
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
p:
- 205.46963709898583
- 0.0
- 320.5
- -14.382874596929009
- 0.0
- 205.46963709898583
- 240.5
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
binning_x: 0
binning_y: 0
roi:
  x_offset: 0
  y_offset: 0
  height: 0
  width: 0
  do_rectify: false
Display the published camera images in rqt
After launching rqt, select “Plugins” → “Visualization” → “Image View”, then choose “/hand_camera/image_raw” from the topic list
$ rqt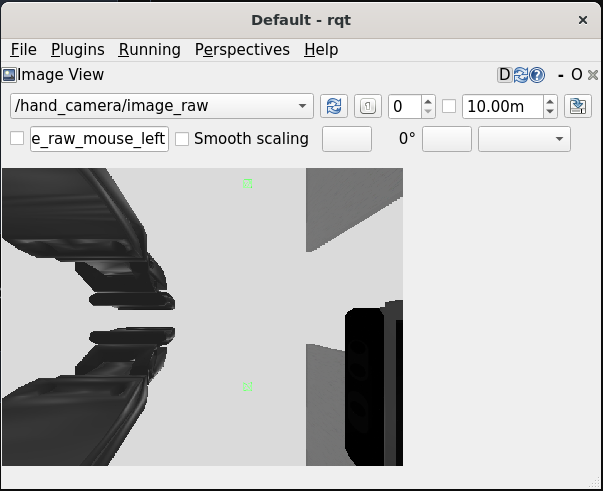
8.1.2.6. Head wide-angle camera#
Note
Available only on HSRB
Get the published camera information
$ ros2 topic echo /head_center_camera/camera_info
header:
  stamp:
    sec: 10068
    nanosec: 857000000
  frame_id: head_center_camera_frame
height: 480
width: 640
distortion_model: plumb_bob
d:
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
k:
- 205.46963709898583
- 0.0
- 320.5
- 0.0
- 205.46963709898583
- 240.5
- 0.0
- 0.0
- 1.0
r:
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
p:
- 205.46963709898583
- 0.0
- 320.5
- -14.382874596929009
- 0.0
- 205.46963709898583
- 240.5
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
binning_x: 0
binning_y: 0
roi:
  x_offset: 0
  y_offset: 0
  height: 0
  width: 0
  do_rectify: false
Display the published camera images in rqt
After launching rqt, select “Plugins”→ “Visualization” → “Image View”, then choose “/head_center_camera/image_raw” from the topic list
$ rqt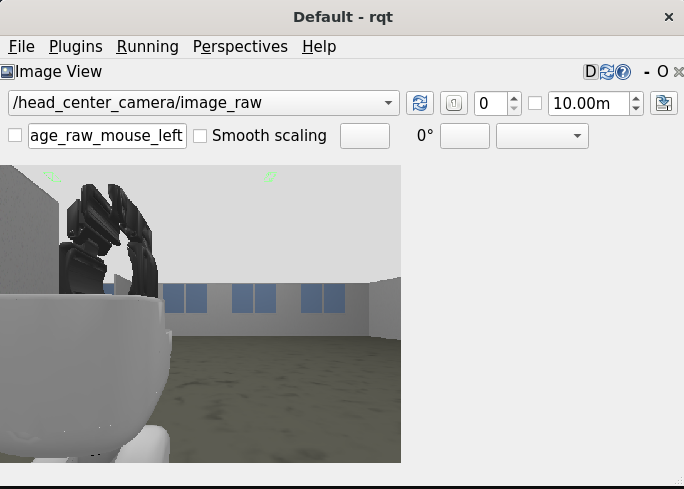
8.1.2.7. Head stereo camera (left)#
Get the published camera information
$ ros2 topic echo /head_l_stereo_camera/camera_info
header:
  stamp:
    sec: 10286
    nanosec: 189000000
  frame_id: head_l_stereo_camera_frame
height: 960
width: 1280
distortion_model: plumb_bob
d:
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
k:
- 968.7653251755174
- 0.0
- 640.5
- 0.0
- 968.7653251755174
- 480.5
- 0.0
- 0.0
- 1.0
r:
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
p:
- 968.7653251755174
- 0.0
- 640.5
- -0.0
- 0.0
- 968.7653251755174
- 480.5
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
binning_x: 0
binning_y: 0
roi:
  x_offset: 0
  y_offset: 0
  height: 0
  width: 0
  do_rectify: false
Display the published camera images in rqt
After launching rqt, select “Plugins”→ “Visualization” → “Image View”, then choose “/head_center_camera/image_raw” from the topic list
$ rqt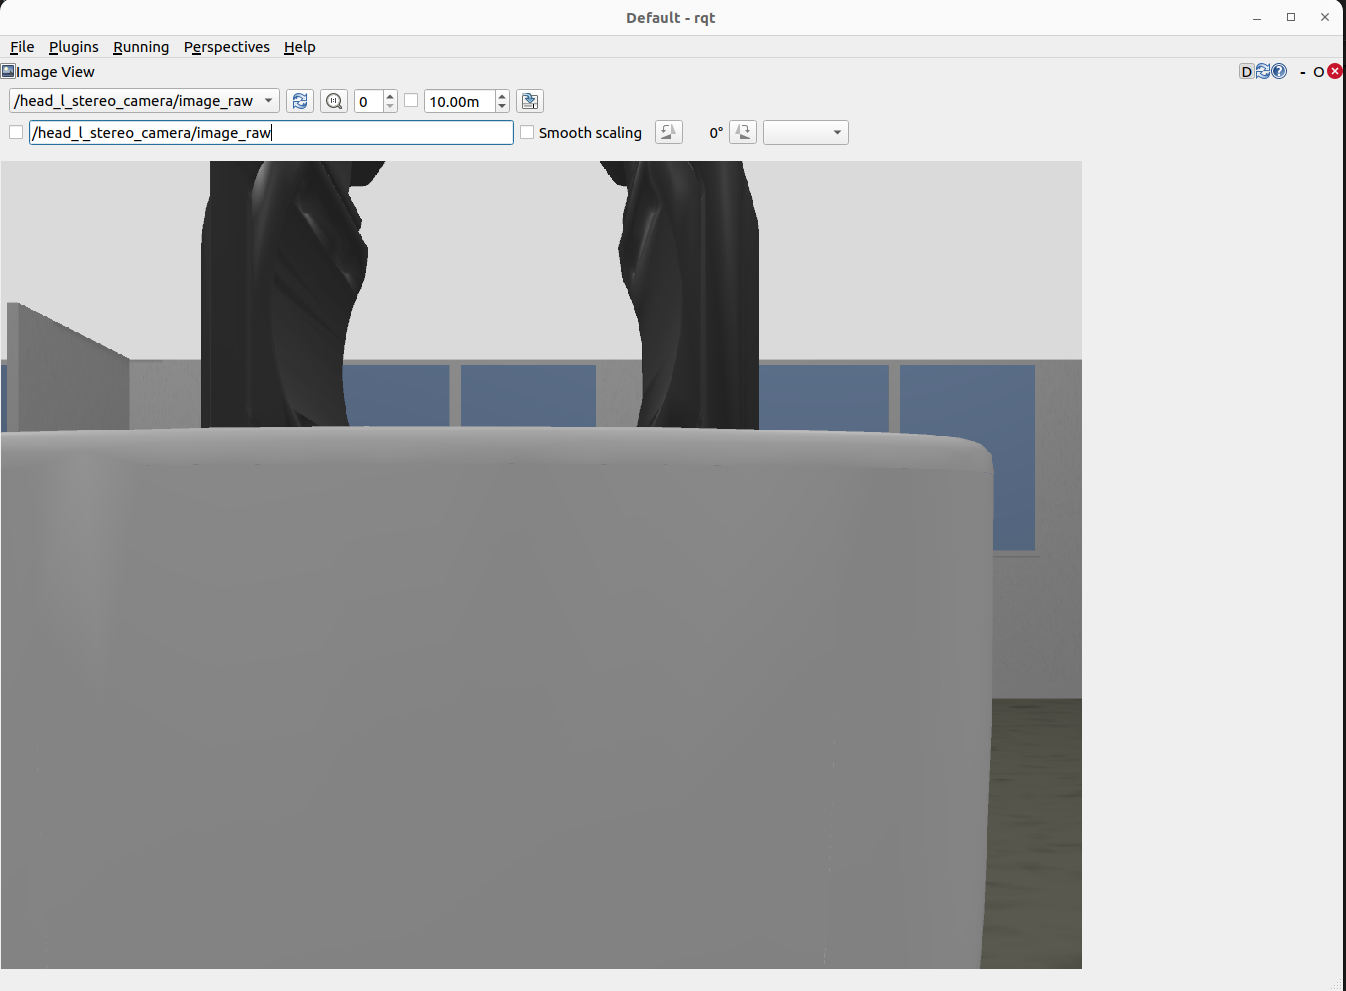
8.1.2.8. Head stereo camera (right)#
Get the published camera information
$ ros2 topic echo /head_r_stereo_camera/camera_info
header:
  stamp:
    sec: 10286
    nanosec: 189000000
  frame_id: head_r_stereo_camera_frame
height: 960
width: 1280
distortion_model: plumb_bob
d:
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
k:
- 968.7653251755174
- 0.0
- 640.5
- 0.0
- 968.7653251755174
- 480.5
- 0.0
- 0.0
- 1.0
r:
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
p:
- 968.7653251755174
- 0.0
- 640.5
- -0.0
- 0.0
- 968.7653251755174
- 480.5
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
binning_x: 0
binning_y: 0
roi:
  x_offset: 0
  y_offset: 0
  height: 0
  width: 0
  do_rectify: false
Display the published camera images in rqt
After launching rqt, select “Plugins”→ “Visualization” → “Image View”, then choose “/head_center_camera/image_raw” from the topic list
$ rqt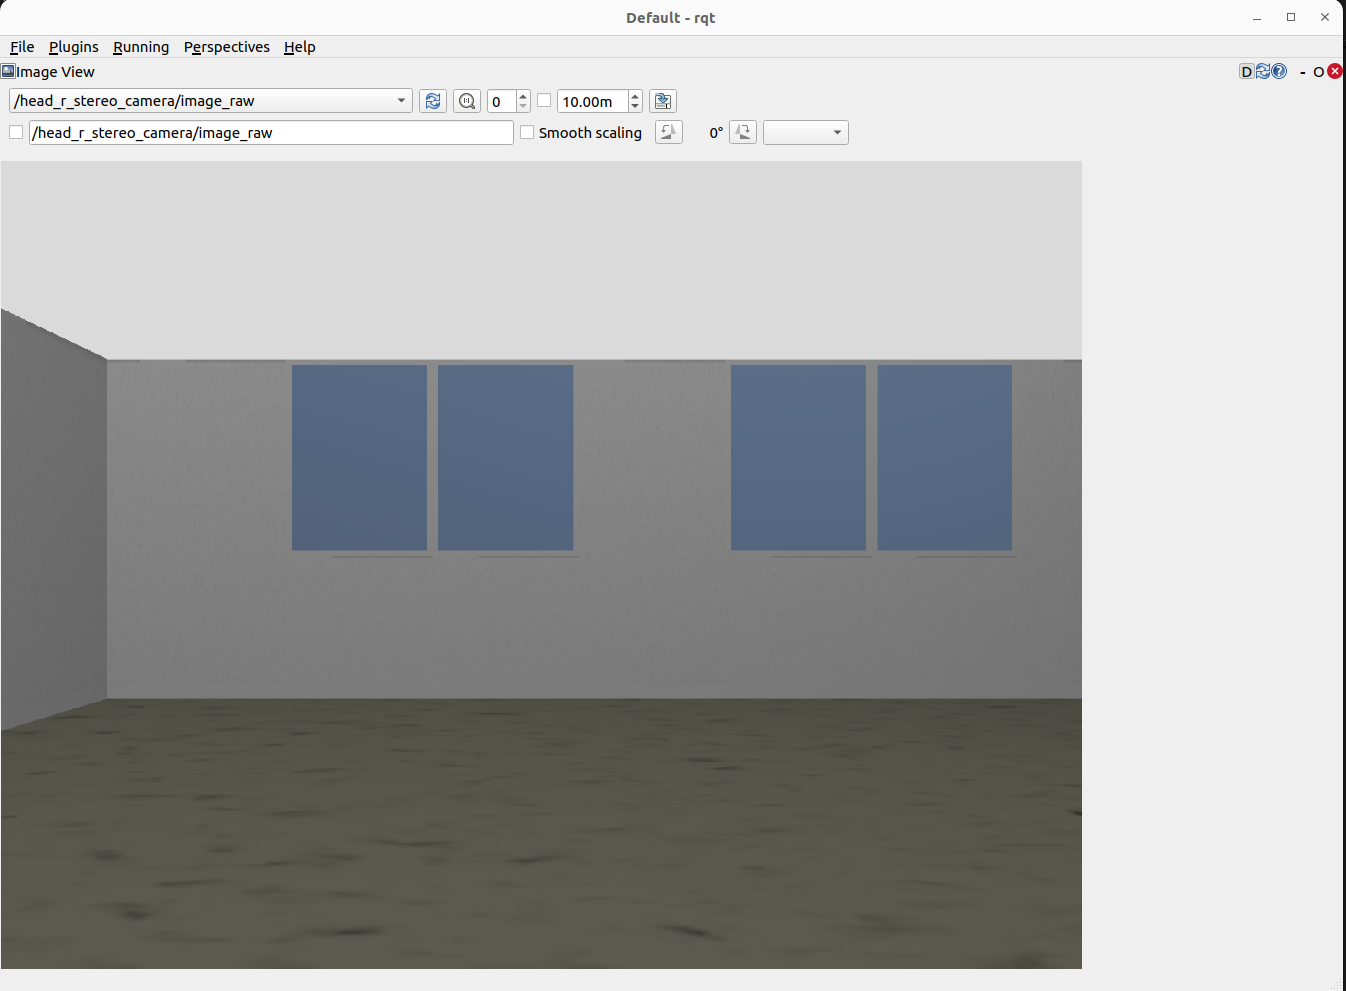
8.1.2.9. Head 3D depth camera#
Get the published RGB camera information
$ ros2 topic echo /head_rgbd_sensor/rgb/camera_info
header:
  stamp:
    sec: 10464
    nanosec: 510000000
  frame_id: head_rgbd_sensor_rgb_frame
height: 480
width: 640
distortion_model: plumb_bob
d:
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
k:
- 554.3827128226441
- 0.0
- 0.0
- 0.0
- 554.3827128226441
- 0.0
- 0.0
- 0.0
- 1.0
r:
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
p:
- 554.3827128226441
- 0.0
- 0.0
- -0.0
- 0.0
- 554.3827128226441
- 0.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
binning_x: 0
binning_y: 0
roi:
  x_offset: 0
  y_offset: 0
  height: 0
  width: 0
  do_rectify: false
Display the published sensor images in rqt
After launching rqt, select “Plugins” → “Visualization” → “Image View”, then choose “/head_rgbd_sensor/rgb/image_rect_color” from the topic list.
$ rqt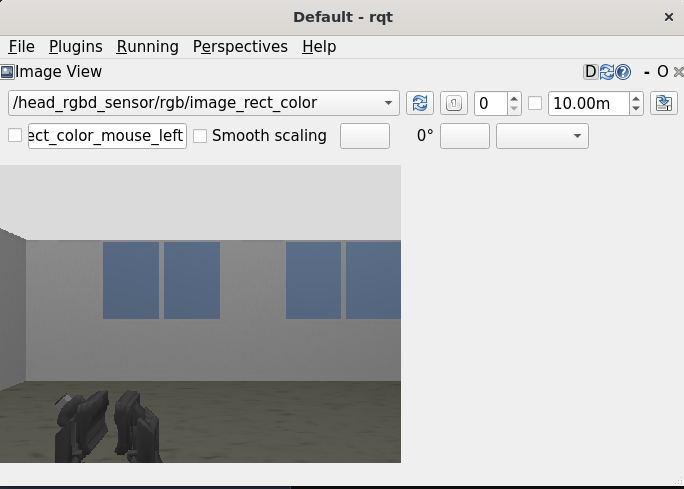
Get the published depth camera information
$ ros2 topic echo /head_rgbd_sensor/depth_registered/camera_info
header:
  stamp:
    sec: 10464
    nanosec: 510000000
  frame_id: head_rgbd_sensor_rgb_frame
height: 480
width: 640
distortion_model: plumb_bob
d:
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
k:
- 554.3827128226441
- 0.0
- 0.0
- 0.0
- 554.3827128226441
- 0.0
- 0.0
- 0.0
- 1.0
r:
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
- 0.0
- 0.0
- 1.0
p:
- 554.3827128226441
- 0.0
- 0.0
- -0.0
- 0.0
- 554.3827128226441
- 0.0
- 0.0
- 0.0
- 0.0
- 1.0
- 0.0
binning_x: 0
binning_y: 0
roi:
  x_offset: 0
  y_offset: 0
  height: 0
  width: 0
  do_rectify: false
Display the published sensor images in rqt
After launching rqt, select “Plugins” → “Visualization” → “Image View”, then choose “/head_rgbd_sensor/depth_registered/image_rect_raw” from the topic list.
$ rqt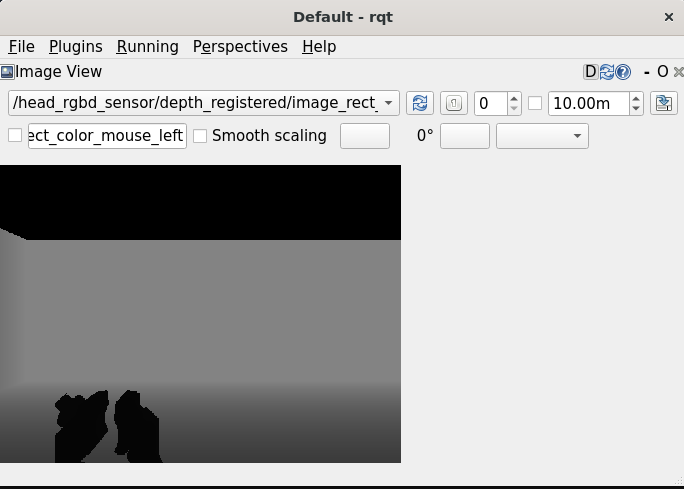
8.1.2.10. Laser scanner#
Retrieve the published laser scanner output.
$ ros2 topic echo  --no-arr /scan
header:
  stamp:
    sec: 11092
    nanosec: 205000000
  frame_id: base_range_sensor_link
angle_min: -2.0999999046325684
angle_max: 2.0999999046325684
angle_increment: 0.005833333358168602
time_increment: 0.0
scan_time: 0.0
range_min: 0.05000000074505806
range_max: 60.0
ranges: '<sequence type: float, length: 721>'
intensities: '<sequence type: float, length: 721>'
8.1.2.11. 6-axis force sensor#
Retrieve the published force sensor output.
$ ros2 topic echo /wrist_wrench/raw
header:
  stamp:
    sec: 11271
    nanosec: 366000000
  frame_id: wrist_ft_sensor_frame
wrench:
  force:
    x: -34.62322695566456
    y: -0.14540779690636907
    z: -1.8011436005398451
  torque:
    x: 0.030794509482329233
    y: -2.105840487050739
    z: -0.018643797444077546
8.1.2.12. Joint state#
Retrieve the published current state of each joint.
$ ros2 topic echo /joint_states
header:
  stamp:
    sec: 1647839284
    nanosec: 624605014
  frame_id: ''
name:
- arm_flex_joint
- arm_lift_joint
- arm_roll_joint
- base_l_drive_wheel_joint
- base_roll_joint
- base_r_drive_wheel_joint
- head_pan_joint
- wrist_flex_joint
- head_tilt_joint
- wrist_roll_joint
position:
- -2.8903283935122204e-06
- 0.19972439991014018
- -1.5700229673346995
- 181.4944573276328
- 3.141743624263463
- 204.7184796245906
- 0.9999903535217216
- -1.5695753709525095
- 0.5002338911119635
- 2.3949704772263658e-05
velocity:
- -0.0009215255691328098
- -0.27647109041567
- -0.022944800640008145
- 0.028210998586525215
- 0.24622042188149748
- 0.02374781245119207
- -0.009186018402255636
- 0.4246389928247181
- 0.23367769165418287
- 0.023994581529605992
effort:
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
- 0.0
8.1.2.13. ControllerManager control#
Retrieve loadable controllers
$ ros2 service call /controller_manager/list_controller_types controller_manager_msgs/srv/ListControllerTypes
requester: making request: controller_manager_msgs.srv.ListControllerTypes_Request()

response:
controller_manager_msgs.srv.ListControllerTypes_Response(types=['controller_manager/test_controller', 'controller_manager/test_controller_failed_init', 'controller_manager/test_controller_with_interfaces', 'diff_drive_controller/DiffDriveController', 'effort_controllers/JointGroupEffortController', 'force_torque_sensor_broadcaster/ForceTorqueSensorBroadcaster', 'forward_command_controller/ForwardCommandController', 'hsrb_base_controllers/OmniBaseController', 'imu_sensor_broadcaster/IMUSensorBroadcaster', 'joint_state_broadcaster/JointStateBroadcaster', 'joint_state_controller/JointStateController', 'joint_trajectory_controller/JointTrajectoryController', 'position_controllers/JointGroupPositionController', 'tmc_ros2_controllers/ExxxDriveModeBroadcaster', 'tmc_ros2_controllers/ExxxDriveModeController', 'velocity_controllers/JointGroupVelocityController'], base_classes=['controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface', 'controller_interface::ControllerInterface'])
Retrieve currently loaded controllers
$ ros2 service call /controller_manager/list_controllers controller_manager_msgs/srv/ListControllers
requester: making request: controller_manager_msgs.srv.ListControllers_Request()

response:
controller_manager_msgs.srv.ListControllers_Response(controller=[controller_manager_msgs.msg.ControllerState(name='joint_state_controller', state='active', type='joint_state_controller/JointStateController', claimed_interfaces=[]), controller_manager_msgs.msg.ControllerState(name='head_trajectory_controller', state='active', type='joint_trajectory_controller/JointTrajectoryController', claimed_interfaces=['head_tilt_joint/position', 'head_pan_joint/position']), controller_manager_msgs.msg.ControllerState(name='arm_trajectory_controller', state='active', type='joint_trajectory_controller/JointTrajectoryController', claimed_interfaces=['arm_lift_joint/position', 'arm_flex_joint/position', 'arm_roll_joint/position', 'wrist_flex_joint/position', 'wrist_roll_joint/position']), controller_manager_msgs.msg.ControllerState(name='omni_base_controller', state='active', type='hsrb_base_controllers/OmniBaseController', claimed_interfaces=['base_roll_joint/position', 'base_r_drive_wheel_joint/velocity', 'base_l_drive_wheel_joint/velocity'])])